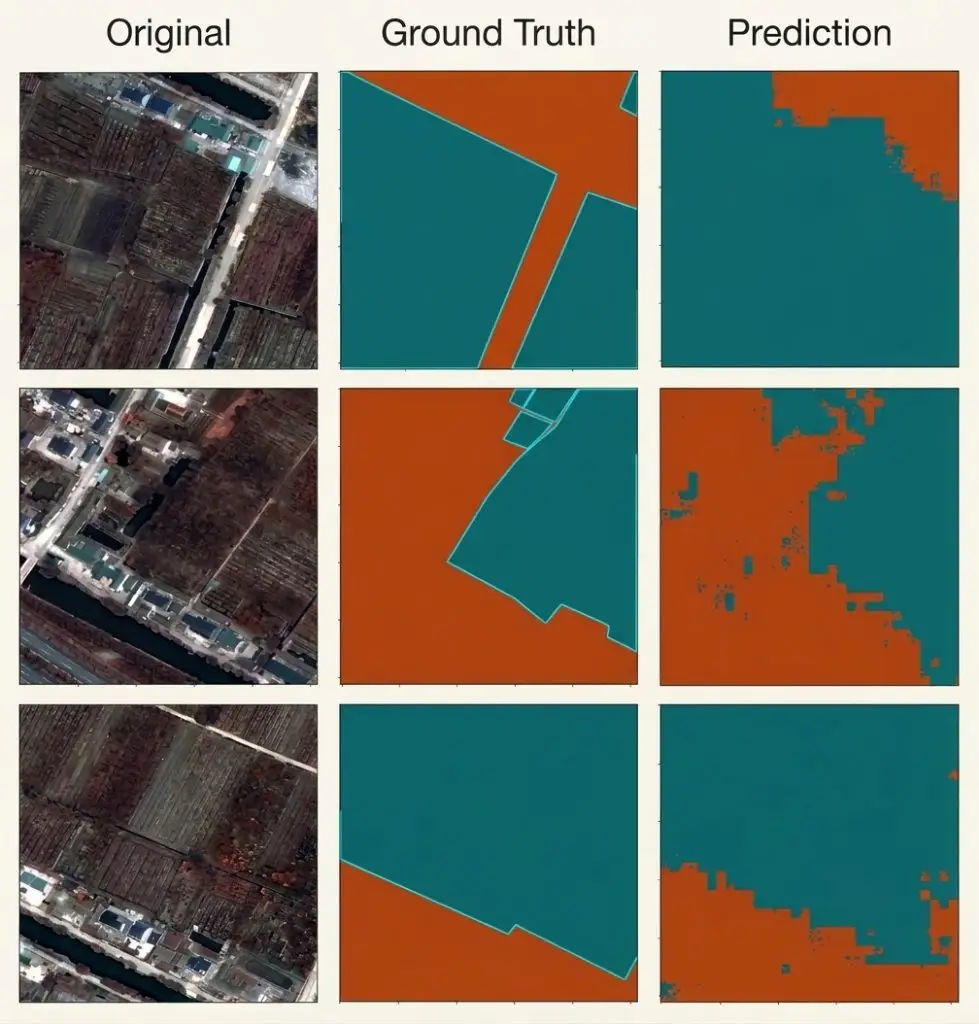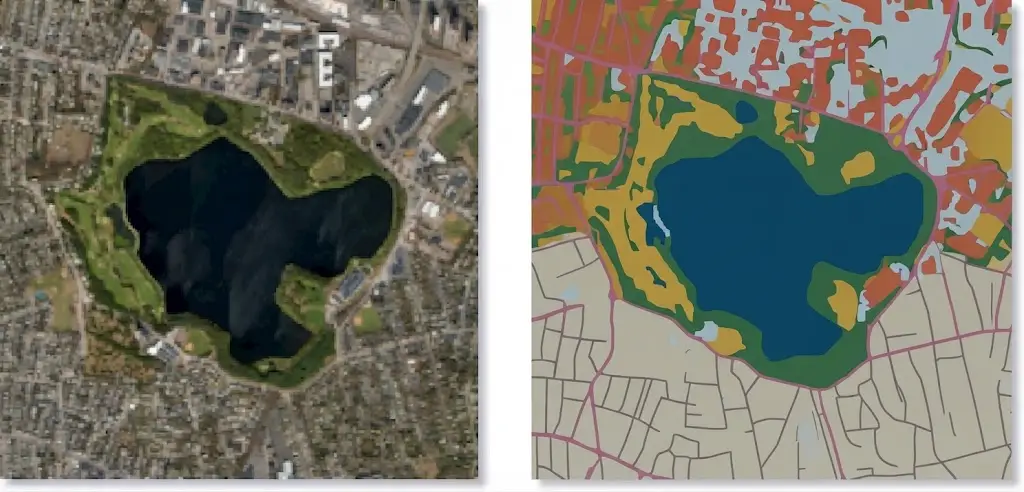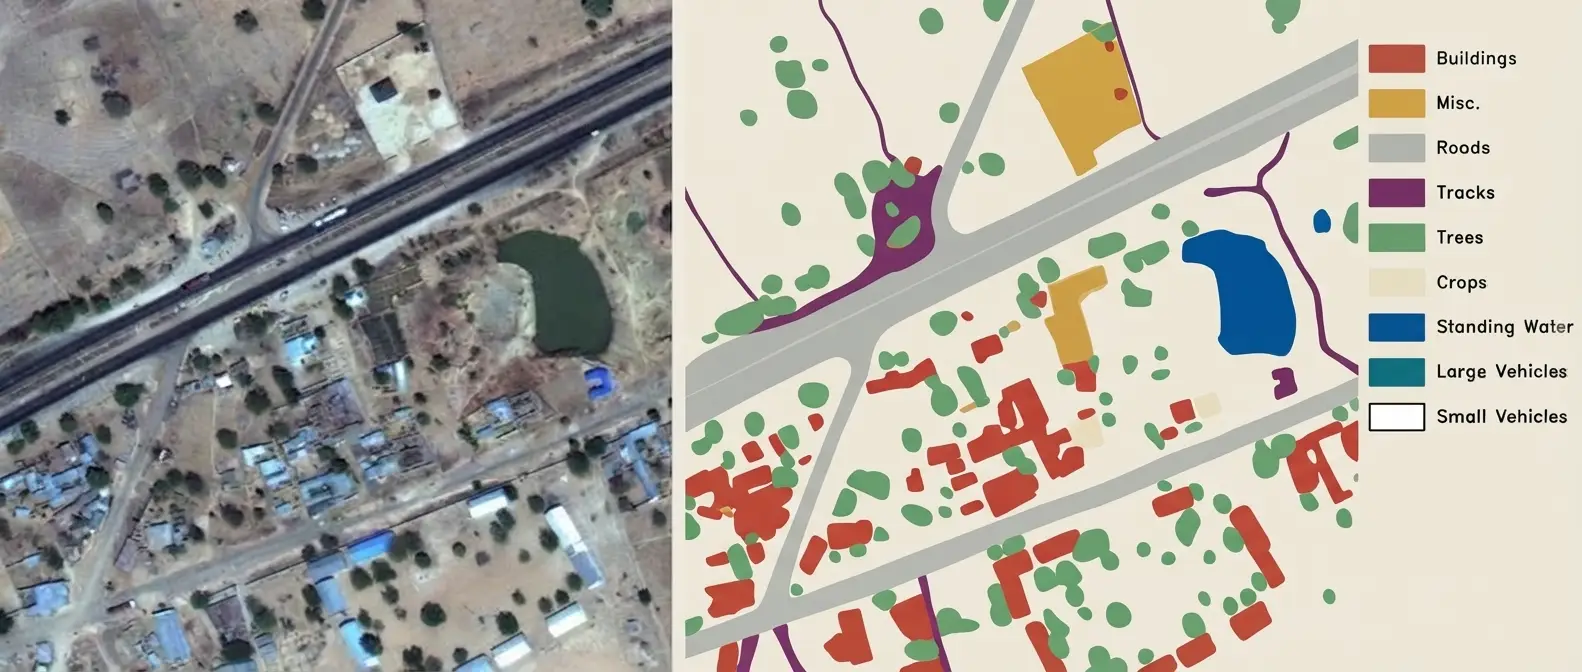
Linear objects are the fourth case in this series on satellite image segmentation, and they pose a problem the previous three did not encounter: their very shape is incompatible with the way a segmentation model treats an image.A road is narrow, very long, connected to other roads, and its interest lies as much in its connectivity as in its footprint. This article sets out those difficulties and the conventions a project must fix. It extends the article on segmenting vegetation.
What makes linear objects different
Five properties distinguish this family in satellite image segmentation.They explain why the methods of the preceding articles apply poorly here.The ratio between length and width is extreme. A road seven metres wide extends over kilometres, producing an object whose area is small and whose extent is considerable.The proportion of boundary pixels is at its maximum. A road three pixels wide contains almost no interior pixels at all, which pushes to the extreme the difficulty the opening article identified as central.Connectivity is in itself a property of the object. An interrupted road network is functionally unusable, where a fragmented parcel remains exploitable.This class is strongly a minority. Roads cover a very small proportion of any territory, which accentuates the imbalance already noted for water.And occlusion is structural. A road passes under trees, under bridges and between buildings, which interrupts its observation without interrupting the object.Why the usual metric misleads
One consequence of those properties deserves setting out first because it invalidates the usual evaluation in satellite image segmentation.An overlap metric measures the proportion of correctly assigned pixels. On a narrow linear object, a one-pixel offset reduces that overlap considerably, while the road is perfectly detected and positioned to within a pixel.Conversely, a one-metre break in a ten-kilometre road affects overlap imperceptibly, while it renders the network unusable for any route calculation.Those two effects combine and produce an absurd situation: the metric penalises heavily what does not matter and ignores what does.Three complementary metrics respond to that difficulty. A tolerance-based measure, which accepts a discrepancy of a few metres and evaluates presence rather than exact coincidence. A connectivity measure, which compares the structure of the predicted network against the reference network. And a break count, which directly measures the most costly failure mode.Surface or centreline
This decision precedes all the others.It determines the nature of the deliverable. A road can be represented by its footprint, meaning the surface it occupies, or by its centreline, meaning a line following its centre.The footprint suits land take calculation, runoff analysis and any surface measurement. It is produced naturally by segmentation and it requires a convention on what is included, carriageway alone or full extent with verges.The centreline suits route calculation, accessibility analysis and integration into a navigation system. It is not produced directly by segmentation and it is obtained by skeletonising a footprint, an operation introducing artefacts of its own.Three difficulties necessarily accompany that conversion. Intersections produce spurious patterns, skeletonisation creating short branches with no reality. Width variations displace the centreline, a local widening shifting the centre. And dual carriageways produce either two centrelines or a median one, according to a convention to be fixed.One practical recommendation follows. Establish at scoping whether the client wants to measure surfaces or calculate routes, a question determining the format, the method and most of the post-processing work.The resolution question
This constraint is more severe here than on any other class.It settles a project’s feasibility. A road must cover several pixels across its width to be reliably delineated, which restates the general rule but applies it to the most constraining dimension.Three resolution bands are distinguishable. At ten metres, only major infrastructure is detectable and then only approximately, a secondary road occupying less than one pixel of width. At a few metres, the main network is detectable and secondary roads remain uncertain. And below one metre, the whole network becomes delineable.An economic consequence follows, identical to the one set out for buildings. A project mapping the complete road network presupposes commercial or aerial imagery, which shifts the cost towards acquisition.One important qualification nonetheless deserves making. A narrow road often remains detectable at a resolution where it is not delineable, its linear signature standing out even across mixed pixels, which permits a mapping of alignment without a mapping of footprint.Occlusion and continuity
This difficulty calls for a response specific to linear satellite image segmentation.The other classes do not encounter it. A road disappears under tree cover, under a bridge, into a tunnel, under a building’s shadow. The object continues and its observation is interrupted.Three attitudes are possible and the choice between them must be explicit.Annotating what is visible produces an interrupted network, faithful to the observation and unusable for route calculation.Annotating continuity produces a functional network, interpolating under occlusions, and introduces an element of inference into data presented as observed.And annotating both, distinguishing observed segments from inferred ones, produces the most honest data and costs more.One important consequence follows for building a corpus. The convention adopted must be identical between training and evaluation, a model trained to interpolate and evaluated against a strictly observed reference being penalised for doing what it was taught.The other linear infrastructures
Four families share these properties.They present specific difficulties worth distinguishing.Railways are narrower than roads and more regular geometrically, which eases their detection through their straightness and their large-radius curves.Watercourses, partly covered in the water article, share the linear geometry and present a different spectral signature, with the difficulty of riparian vegetation masking them.Power lines are practically undetectable directly, their width being nil at any satellite resolution, and they are located through their cleared corridor and their pylons.And buried pipelines are not observable at all, except through the vegetation or soil trace they sometimes leave at the surface.Those last two families deserve a commercial qualification. A client asking for a mapping of buried networks from imagery is asking for something imagery does not supply, and that point belongs at scoping.Network hierarchy in satellite image segmentation
This nomenclature mixes the observable and the non-observable.Three classification criteria coexist and they do not overlap at all.The physical criterion rests on width, lane count and surfacing. It is directly observable and it constitutes the most reliable level.The functional criterion rests on the role in the network, motorway, main road, local access. It is partly observable, width and connectivity giving indications without determining it.And the administrative criterion rests on legal status and managing authority. It is not observable at all.One recommendation follows, identical to the one made for the vegetation class. Establishing which criterion the request attaches to avoids an impossible project, a client frequently asking for an administrative classification while assuming it is deducible from the image.Existing references
This particularity changes a project’s economics.Road networks are the subject of some of the most complete and accessible databases in the geospatial field, produced by administrations and by collaborative projects.Three uses follow directly for a satellite image segmentation project. Those databases serve as reference for evaluation, with the usual precautions on date and geometric convention. They serve as a starting point for updating, which turns production into change detection. And they serve as a training source, an automatic alignment between database and imagery producing a corpus at low cost.That third use nonetheless calls for an important caveat. Alignment between a vector database and an image carries discrepancies, both of georeferencing and of date, producing a noisy corpus whose quality must be measured before use rather than assumed.One important observation completes that. Coverage of these databases is very uneven, excellent in countries where the administration or the community is active and patchy elsewhere, which matches the geographic disparity research has documented.Uses and their requirements
Five uses employ this class in satellite image segmentation, with markedly different requirements.Map updating demands change detection and good geometric precision, the aim being to complete an existing database.Accessibility analysis demands correct connectivity and tolerates alignment imprecision, route calculation mattering more than exact position.Land take assessment demands a footprint rather than a centreline, surface being the object of the measurement.Disaster response demands rapid detection of cuts, a comparison exercise rather than a mapping one and one matching the uses described in the previous series.And infrastructure development monitoring demands a time series and an ability to detect alignments under construction, whose appearance differs from a completed road.Post-processing, a major part of the work
It shifts the distribution of effort in a satellite image segmentation project.A model’s raw output is rarely deliverable for a linear object, where it often is for a surface. Five distinct operations separate it from a usable product.Noise removal, which eliminates small wrongly detected regions and which must spare legitimate short segments.Gap filling, which reconnects interrupted segments under a distance and alignment criterion, a delicate operation since an abusive reconnection creates a road that does not exist.Thinning, which produces a centreline from a footprint with the difficulties set out above.Simplification, which reduces a line’s point count without altering its shape beyond a documented tolerance.And topological construction, which establishes nodes at intersections and produces a graph usable for route calculation.One practical consequence follows. On this class, post-processing can represent as much effort as the segmentation itself, which should appear in a quotation rather than remain implicit.The conventions to fix
Seven decisions must be settled before production, and omitting them produces substantial variability.The object represented, footprint or centreline, the most decisive decision.The extent of the footprint, carriageway alone, carriageway and verges, or full land parcel.The treatment of occlusions, under the three attitudes set out above.The treatment of intersections, junctions and interchanges, whose representation as surface and as centreline differ profoundly.The width or importance threshold below which a road is not represented.The treatment of unsurfaced tracks and paths, whose inclusion depends on the purpose and whose detection is markedly harder.And the treatment of dual carriageways, represented by one object or two.The approaches specific to linear objects
Research in satellite image segmentation has developed methods specific to this family.It is worth knowing their principle.Weighted loss functions give greater weight to boundary and connection pixels, which offsets the imbalance described and directs learning towards what matters.Topological approaches add to the learning a term measuring preservation of network structure, which explicitly penalises a break independently of its pixel cost.And graph-based approaches abandon pixel segmentation and directly construct a network of nodes and edges, which guarantees correct topology by construction and complicates handling irregular geometries.One observation runs across those three families and it matters for a data provider. All require a reference whose topology is correct, which raises the demand on the corpus: an annotation containing unintended breaks teaches the model to produce them.That requirement justifies the network traversal check recommended below, rather than a check by area sampling.The cost of annotating a network
It differs markedly from the other satellite image segmentation classes.Three characteristics distinguish it.Annotation is long by nature. Tracing a road several kilometres long means following an alignment over its whole length, which takes a time proportional to distance rather than to area.The precision required is low across the width and high in continuity. An annotator can be approximate at the edges and must be rigorous in following, which inverts the usual priorities.And fatigue produces characteristic errors. Following a long alignment is a repetitive task where attention drops, producing breaks and jumps at the end of a session rather than at the start.Three levers effectively reduce that annotation cost. Pre-annotation from an existing database, which turns tracing into verification. Assisted tracing tools, which automatically extend an alignment for the annotator to correct. And splitting the work into short sessions, which addresses the fatigue difficulty set out above.One consequence for quality control follows. Checking by random area sampling suits this class poorly, a check by network traversal detecting better the breaks that constitute the dominant failure mode.The failure modes to track
A global satellite image segmentation score distinguishes none of them.Five deserve tracking separately.The break, one segment detected as two pieces, the most costly failure mode functionally.Complete omission, an entire road undetected, frequent on narrow roads and unsurfaced tracks.Linear false detection, an elongated object taken for a road, parcel boundaries, canals and hedgerow shadows producing this type of error.Alignment offset, a systematically displaced centreline, which signals a georeferencing problem or a footprint convention differing between reference and production.And intersection error, a badly reconstructed junction, which barely affects surface and makes a route calculation wrong.One practical consequence follows. Reporting those five modes separately is more informative than a single figure, and that decomposition directs correction where a global score indicates nothing.Approaching a network project
Four questions scope a linear satellite image segmentation project and they take one meeting.Does the client want to measure surfaces or calculate routes. That settles footprint against centreline, and with it the delivery format and most of the post-processing.Does a reference database exist over the area. Its presence turns production into updating, which divides the cost, and its absence signals a region where the work’s value will be correspondingly higher.What is the smallest road that must appear. That answer determines the resolution required and therefore the source, a decision weighing more on the budget than annotation itself.And what should happen under occlusions. That question looks technical and it is functional, a client calculating routes needing a continuity a client measuring surfaces does not want.Those four answers determine the source, the convention, the evaluation metric and the volume of post-processing. Asking them before drafting a proposal produces a document that describes the right product.What this use case teaches
This observation completes the three preceding ones.Four classes have been examined and they illustrate four distinct difficulties.Water poses a difficulty of definition. Buildings pose a difficulty of geometry. Vegetation poses a difficulty of observability. And linear objects pose a difficulty of measurement: what matters is not what the usual metric measures.That fourth difficulty deserves generalising because it holds beyond this class. A standard metric encodes an implicit definition of quality, and that definition may not match the client’s.Three questions allow this to be checked on any class. What discrepancy would the client notice. What discrepancy would cost them something. And does the metric used penalise them in proportion to that cost.On linear objects the answer is plainly no, which makes the problem visible. On other classes the gap exists too and it is more discreet, which makes it more dangerous.Why this class benefits most from existing data
One economic observation about satellite image segmentation closes the practical side, since it changes how a road project should be approached.Of the four classes examined in this series, roads are the one where existing reference data is most complete and most accessible. That has three consequences a project should exploit rather than ignore.The realistic default is updating rather than mapping. Where a database exists, producing a network from scratch duplicates work already done, and the useful product is what has changed since the database was built.The corpus can be largely inherited. Aligning an existing network onto imagery produces training data at a fraction of the cost of tracing, subject to measuring the noise that alignment introduces.And the value concentrates where the data is absent. Regions with patchy coverage are precisely those where a road product has most operational worth, which matches the geographic pattern the previous series documented across every class.That third consequence is the commercially significant one. A provider able to work where reference data does not exist is not competing with the database; it is supplying what the database has never covered.Common mistakes
These failures recur often enough that naming them is usually enough to avoid them.- Evaluating a linear network with a simple overlap metric.
- Neglecting connectivity, which is the most costly failure mode.
- Delivering a footprint to a client who wants to calculate routes.
- Skeletonising without handling intersection artefacts.
- Targeting a complete network at a resolution that does not distinguish it.
- Using different occlusion conventions between training and evaluation.
- Asking for an administrative classification from the image.
- Aligning a vector database on imagery without measuring the noise produced.
- Promising a mapping of buried networks from imagery.
- Handling unsurfaced tracks with the means designed for roads.
- Checking quality by area sampling rather than by network traversal.
- Omitting post-processing from a quotation when it is a major part of the work.